Train in Simulation, Deploy on a Real Robot: Microduck with Isaac Lab 3.0
3.42T1.5 sourceHugging Face Blog
Source record
Published by Hugging Face Blog (T1.5 source). The original is at https://huggingface.co/blog/nvidia/microduck-isaac-lab-sim-to-real.
Pipeline notes
The summary and note below are generated by the signal pipeline — they are Beyond Desk’s reading, not quotations from the source.
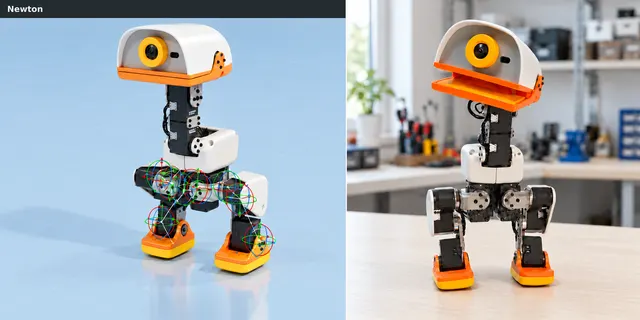
SummaryNVIDIA and Hugging Face announce Microduck, an affordable open-source bipedal robot from Pollen Robotics, with a tutorial to train walking policies in Isaac Lab 3.0 and Newton simulation, export as ONNX, and deploy on the real robot. Models can be shared on the Hugging Face Hub or submitted to the Microduck Arena competition.
Why it mattersConcrete sim-to-real deployment pipeline for a new open-source biped robot, with the tools, export format, and sharing hub specified.
Cited by
No citations on record.